SYD Dynamics offers standard products as well as complete motion and navigation solutions. The TransducerM product line consists of standard units for IMU / AHRS / INS applications.

SYD Dynamics TransducerM  is a complete solution for motion sensing applications, capable of providing computed data for determining orientation of an object in 3D space.

Out-of-box, it provides orientation data in terms of Euler angles, Quaternion, and, most commonly used Roll/Pitch/Yaw all of which can be computed with the reference to world frame (based on Earth’s magnetic field and gravity direction). It can also output calibrated raw sensor data, including angular rate, acceleration and magnetometer measurement [1].

The magnetometer is equipped with 'Active Magnetic Field Compensator' to detect and remove disturbances and ensure a stable heading.

TransducerM TM1XX and TM4XX series with OEM circuit board design or mechanical enclosure. Providing inertial measurement reference data and with Serial interface. Target applications: electronics on volume production. The compact size allows for easy integration. Customized designs are also possible.
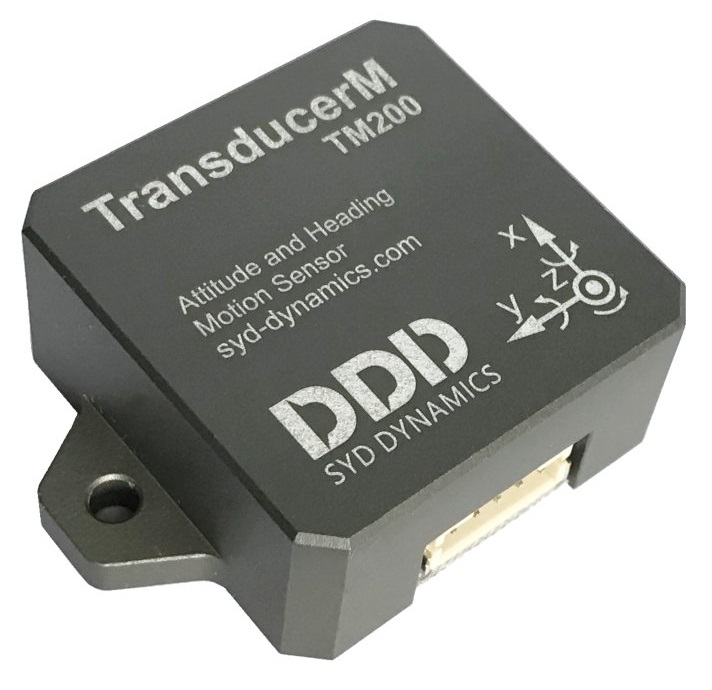
TransducerM TM151/TM171

TransducerM_TM200

TransducerM TM2XX series is a 3D Attitude and Heading Reference System (AHRS)  with aluminum enclosure,  offering better performance than the OEM version. It features medium-level shock resistance and a configurable motion profile. It provides inertial measurement reference data and with its Serial interface.

Target applications: Consumer products, laboratory, robotics, hobby and education.

TransducerM TM200 is Attitude and Heading Reference System (AHRS) with a 9-axis IMU for typically Autonomous Guided Vehicle (AGV) applications and simple mechanical control.

TransducerM TM210 is an Attitude and Heading Reference System (AHRS) with a 9-axis IMU. It is the new iteration with improved performance of the TM200 model.

TransducerM TM210-G is Z-Axis gyroscopes for typically Autonomous Guided Vehicle (AGV) applications and simple mechanical control.
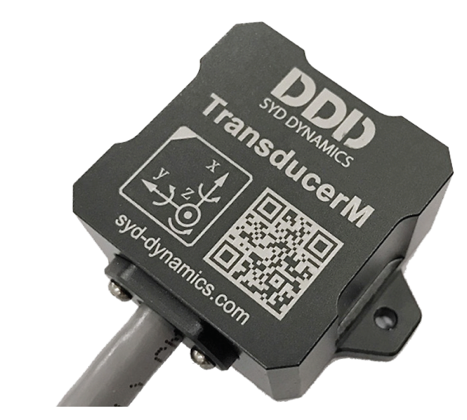
TransducerM TM200

TransducerM TM210

TransducerM TM210-G/TM210-GP

Picture1
TransducerM TM352/TM353 features high performance and a rugged design. It procides  inertial measurement reference data and with Serial and CAN Bus interfaces. Target applications: Indoor and outdoor autonomous vehicles, robotics, and drones. Features shock resistance design, motion profile configuration and calibration software interface for better performance with ground vehicles on heading stability.
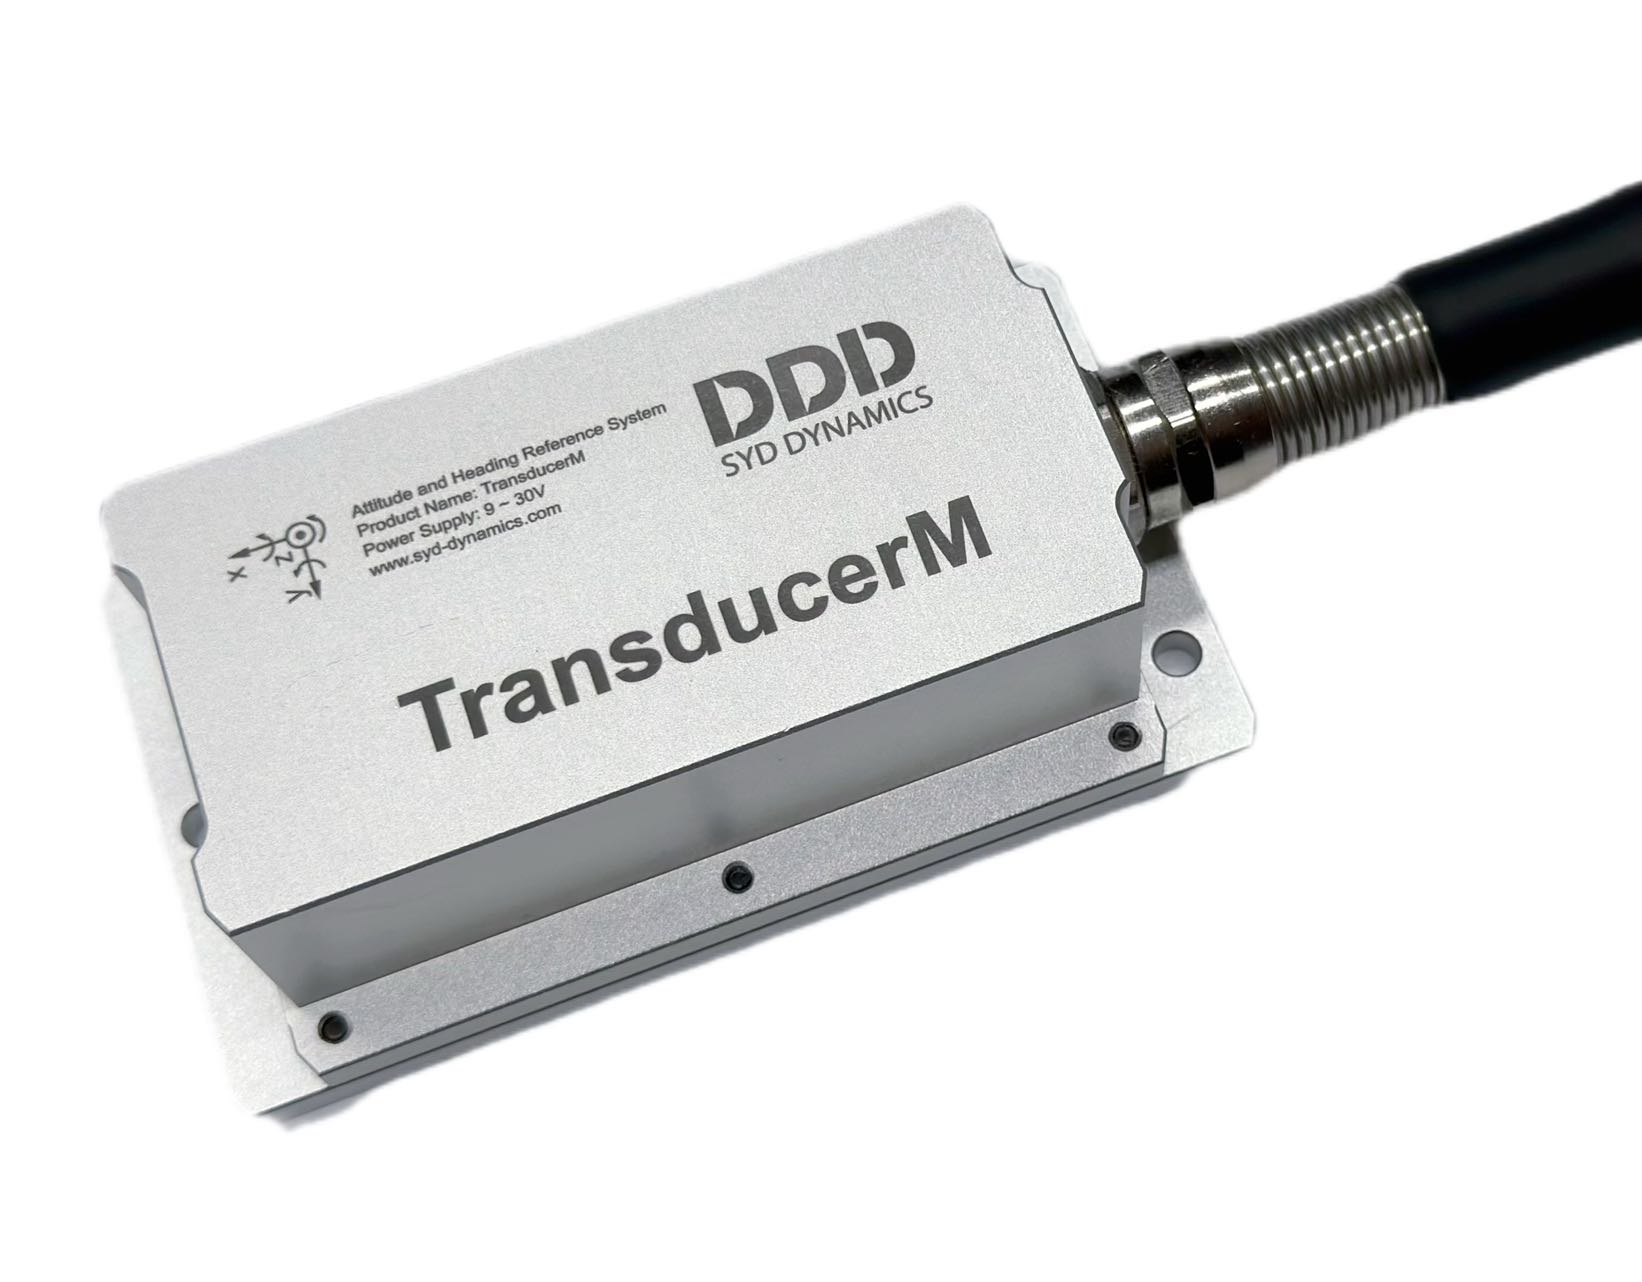
TransducerM TM352/TM353

TransducerM TM362/TM362-P

TransducerM TM500 High-Performance-Series with or without rugged design. Providing high accuracy inertial measurement reference data with Serial RS422, USB 2.0 and CAN Bus interfaces. Target applications: Indoor and outdoor autonomous vehicles, robotics and drones under strong vibration with wide operation temperature range; precision motion measurement.

Contact us for details

Products comparison as below[2]


PRODUCT SERIES
(Typical models. Some models are not listed below, such as TM131, TM210-G, TM230, TM362-P, TM4xx Series)

FEATURES

TransducerM
TM1XX
(TM151/TM171)

TransducerM
TM2XX
(TM200/TM210)

TransducerM
TM3XX
(TM352/TM353/TM362/TM310)

TransducerM
TM5XX
 

Sensors

3-Axis: Gyroscope and Accelerometer

●

●

●

●

3-Axis: Magnetometer

●

●

●

●

Features

Sensor Fusion

●

●

●

●

Sensor Fusion Profiles

-  (TM151)

● (TM171)

●

●

●

Vibration Resistant

● (Basic)

● (Basic)

●(Mid)

● (Full)

Configuration GUI

●

●

●

●

Run-time calibration API

●

-  (TM200)

● (TM210)

●

●

Digital Compass Function

●

-  (TM200)

● (TM210)

-  (TM352/353)

      ● (TM362/TM310)

●

Essential Factory Calibration

●

●

●

●

Thermal Calibration

-

 - (TM200)

- (TM210)

 ●(TM210-T1/T2)

-  (TM352/TM353)

● (TM362/TM310)

●

Interfaces

UART

●

●

●

-

CAN Bus

-

-

●

●

USB

●

-  (TM200)

● (TM210)

-  (TM352/TM353/TM310)

      ● (TM362)

○

Output

Calibrated Raw Data Output

●

●

●

●

Roll, Pitch, Yaw Output

●

●

●

●

Max Output Data Rate (ODR)

400Hz (TM151)

800Hz (TM171)

Approx. 200Hz  (TM200)

800Hz (TM210)

Approx. 200Hz  (TM352/TM353)

800 Hz  (TM362)

200-800Hz

Precision ODR selectable by Hz

●

-  (TM200)

● (TM210)

 -  (TM352/TM353)

 ● (TM362/TM310)

●

Performance

Static Accuracy (Roll-Pitch)[3]

0.5°RMS

0.7°RMS (TM200)

0.4°RMS (TM210)

0.5°RMS (TM352/TM353)

0.3° RMS (TM362)               

0.2°~0.5° RMS

Yaw Drift[3]
Typical city car driving dynamic condition, including sharp and slow turning, slopes, with fast and gentle accelerations and traffic light stops, tested when QoS
reaches 5. Actual performance may vary. 

Typical 3.0° error every 25 minutes (TM151)

Typical 2.6° error every 25 minutes (TM171)

Not rated (TM200)

Typical 2.6° error every 25 minutes (TM210)

Not rated (TM352/TM353)

Typical 2.6° error every 25 minutes (TM362)

Typical 1.4°~ 2.5° error every 25 minutes

Dynamic Accuracy (Roll-Pitch)[3]

1.5°RMS (TM151)

1.0°RMS (TM171)

2.5°RMS(TM200)

0.9°RMS(TM210)

2.0°RMS(TM352/TM353)

0.8°RMS (TM362)

0.3° ~ 0.5°RMS

Operation Condition

Temperature

-40~85°C

-40~85°C

-40~85°C

-40~85°C

Voltage

5V

5V

5V, or 5~32V

5V, or 9~36V, or 9~30V

IP Rate

PCBA
Unprotected

Module
Up to IP50

IP67

IP67

Application

Consumer,
Education,
Laboratory,
Hobby

Consumer, Education,
Laboratory,
Hobby, Commercial application

Commercial application,
Laboratory

Commercial application,
Heavy-duty-Industrial,

Laboratory

Standard Warranty

1 year

1 year

1 year

1~3 year(s)

Extended Warranty

-

-

○

○

● Standard         ○ Optional         − Not Available

________________

[1]  For accelerometers and magnetometers, they are calibrated to ‘units’ and are accurate in terms of vector direction but not their absolute values. E.g. accelerometer may output 1.0 meaning equal to earth gravity magnitude.
[2] Specifications are subject to change without notice. Not all models are listed. The latest version takes precedence over any conflicting information herein.
[3] According to tests in laboratory environment, typical performance. Actual performance may vary.